Mohak sequence
Real robot
ICLR 2027 Submission
Neural Contact-Consistent Retargeting for Whole-Body Humanoid Tracking
Under review as a conference paper at ICLR 2027
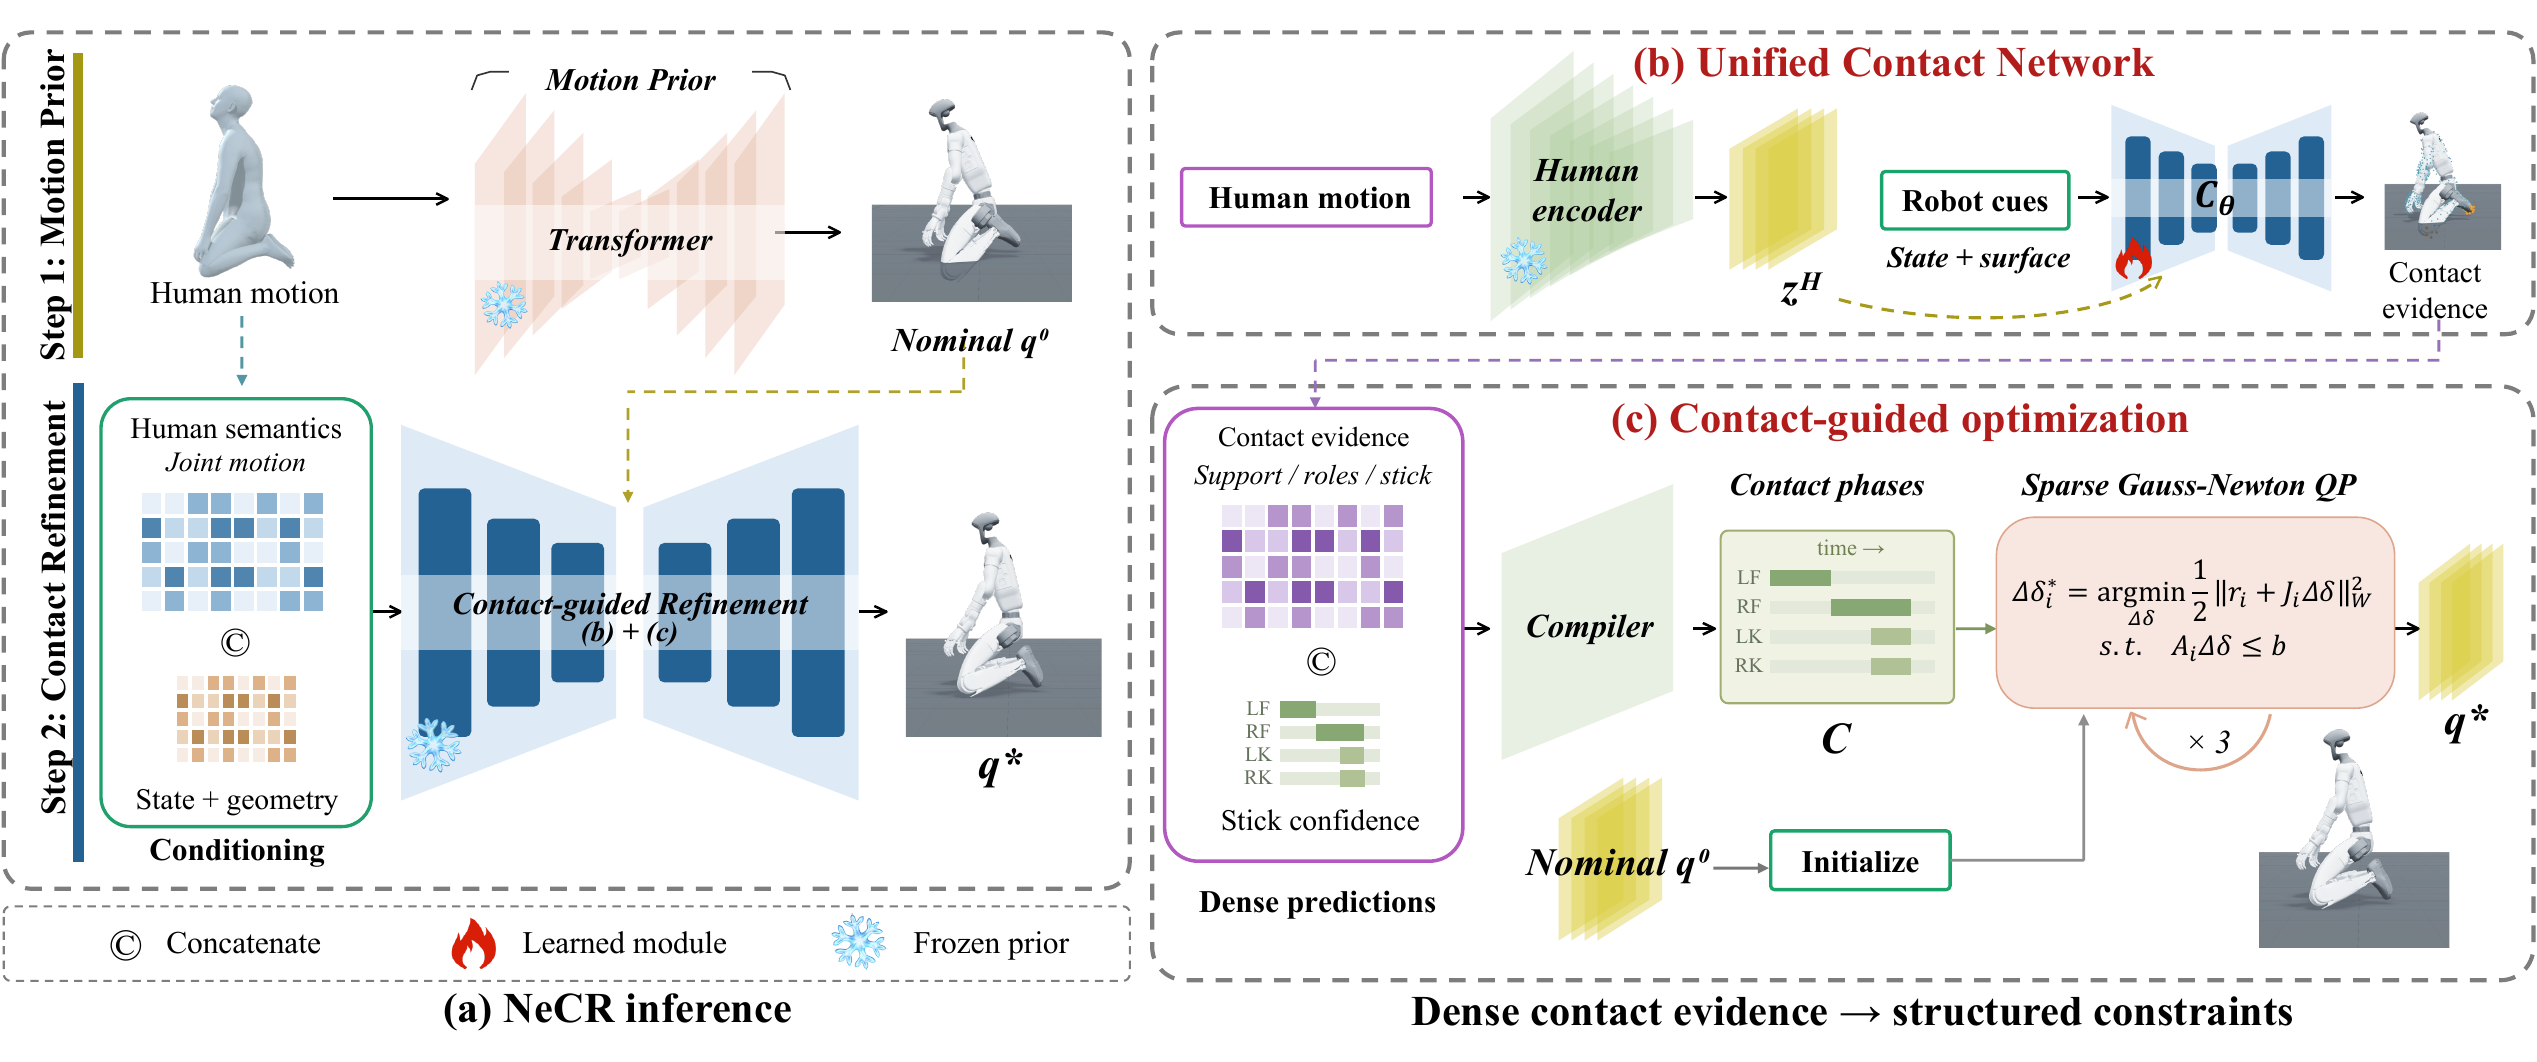
Human-to-humanoid motion retargeting converts human motion into reference trajectories for humanoid control. Learning-based methods transfer motion semantics efficiently but enforce nothing at inference, while optimization-based methods enforce constraints but can settle on a pose that breaks the supporting contact. What is missing is the signal that tells the optimizer where correction is needed, over which intervals, and with what confidence. We present NeCR, a hybrid neural-optimization framework for contact-consistent motion retargeting. NeCR first predicts a semantically faithful nominal robot trajectory. A surface-conditioned temporal model then predicts continuous whole-body contact modes. Conditioned on them, correction reduces to a sparse, block-banded proximal projection that adjusts only support-relevant degrees of freedom. On public datasets retargeted to a Unitree G1, physical correction becomes nearly free: penetration is nearly eliminated and support-phase sliding falls from 20.6% to 4.4% at a cost of 0.16 cm MPKPE, and NeCR runs at 5.9 ms per frame end to end, over five times faster than real time at 30 Hz. The resulting references are also more trackable, improving policy success across two independently implemented trackers and under cross-reference evaluation. A proprioceptive policy trained on them transfers zero-shot to a real Unitree G1 on whole-body-contact motions such as crawling and fall recovery. Code, retargeted datasets, and trained policies will be released.
 Hover or tap to flip
Real-to-sim pairs
Each row pairs a real Unitree G1 deployment with its corresponding simulation result for direct comparison.
Real robot
Simulation
Real robot
Simulation
Self comparison
Each clip compares the human reference, the nominal robot motion from the initial retargeting network (blue), and the complete NeCR result (black-and-white solid robot).
Side view
Side view
Side view
Looped sequence · side view
Side view
Front view
Qualitative comparison
Each synchronized video compares the human reference with GMR, OmniRetarget, NMR, and NeCR on the same motion.
Fast acrobatic motion with large whole-body rotation.
Human · GMR · OmniRetarget · NMR · NeCRA compact pose sequence with challenging lower-body articulation.
Human · GMR · OmniRetarget · NMR · NeCRRhythmic whole-body motion with coordinated arms and legs.
Human · GMR · OmniRetarget · NMR · NeCRRapid transition from standing to body-ground contact.
Human · GMR · OmniRetarget · NMR · NeCRDynamic forward motion with takeoff, flight, and landing.
Human · GMR · OmniRetarget · NMR · NeCRVertical whole-body dynamics and coordinated landing.
Human · GMR · OmniRetarget · NMR · NeCRExpressive upper-body motion around a stable support pose.
Human · GMR · OmniRetarget · NMR · NeCRDeep-knee motion with a low center of mass.
Human · GMR · OmniRetarget · NMR · NeCRLarge-range articulated motion across the full body.
Human · GMR · OmniRetarget · NMR · NeCRSteady locomotion with repeated support transitions.
Human · GMR · OmniRetarget · NMR · NeCRA fast locomotion sequence followed by a dynamic fall.
Human · GMR · OmniRetarget · NMR · NeCRWhole-body locomotion with sustained hand and knee contacts.
Human · GMR · OmniRetarget · NMR · NeCRInteractive demo
Compare each human reference with the synchronized NeCR retargeting result across the first 1,600 frames.
Dance 1 · dance1_subject1